
AI‑Powered Bicycle Learns to Perform Batman‑Style Stunts
A new robotic bicycle, called Ultra Mobility Vehicle, uses a moving mass for balance and has learned to wheelie, leap, and flip, potentially informing future ultra‑agile personal transport and deliver
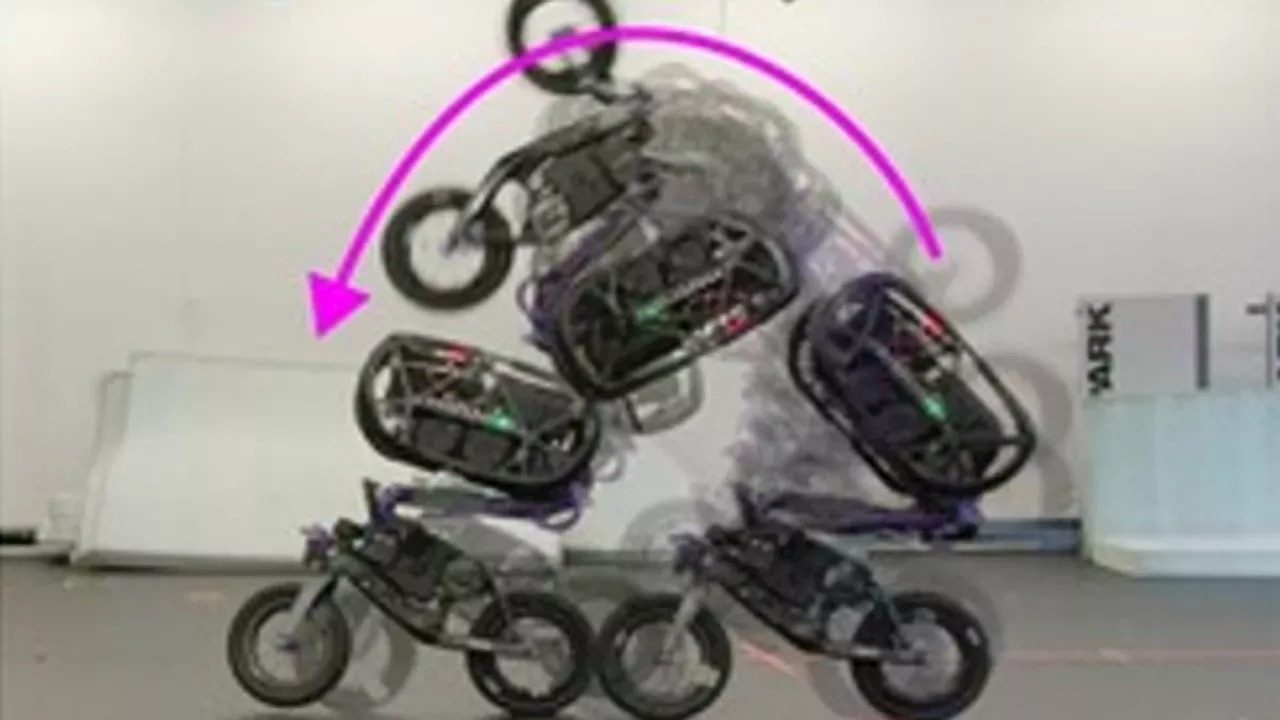
AI‑Powered Bicycle Learns to Perform Batman‑Style Stunts A new robotic bicycle, called Ultra Mobility Vehicle, uses a moving mass for balance and has learned to wheelie, leap, and flip, potentially informing future ultra‑agile personal transport and delivery robots. Scientists at the Robotics and AI Institute in Massachusetts have unveiled a new robotic bicycle that can perform wheelies, jump over obstacles, and even execute front flips-stunts that echo those seen on Batman's Batpod. Dubbed the Ultra Mobility Vehicle (UMV), the machine is built on a two‑wheel bicycle chassis but incorporates a powerful moving mass that shifts its weight mid‑maneuver, allowing it to balance and generate the momentum required for high‑energy tricks. Unlike many robots that rely on multiple wheels, stabilisers or electronic "reaction wheels" to maintain balance, the UMV relies on continuous weight shifting and physics‑based control to stay upright.AI Learns Balancing ManeuversThe design was inspired by mountain bikers and trail riders who use a combination of hopping, tracking and balanced riding to navigate rough terrain efficiently. In a publication in Science Robotics the team described how the robot's "head"-a movable mass mounted above the frame-acts like a rider's body, enabling it to counterbalance during turns, slides or when it performs a 'shimmy turn', a maneuver that emerged naturally from the AI's learning process rather than being explicitly programmed.The researchers used a combination of computer simulations and reinforcement learning to test dozens of layout options and settle on an optimal design. The UMV weighs 23.5 kilograms and can reach speeds of eight metres per second. It can jump over obstacles that are 130 percent of its own height, a remarkable feat for a two‑wheel platform.During training in a virtual environment the robot practised thousands of manoeuvres, learning to ride forward and backward, balance in a stationary track stand, hop sideways on a single wheel and turn on the spot. The real‑world prototype demonstrated these skills on both level ground and uneven terrain, autonomously locating an obstacle, leaping onto a one‑metre platform, traversing it and jumping off the opposite side.Future Applications in Urban DeliveryWhile the current prototype is not large enough to carry a human, the underlying technology could inform the development of ultra‑agile personal transport devices that can negotiate stairs, uneven sidewalks or delivery routes where conventional bicycles or scooters cannot go. The design's small spatial footprint, coupled with its speed and dynamic stability, makes it suitable for urban delivery drones or reconnaissance robots tasked with traversing rough terrain.The team also highlighted the potential for future iterations to carry payloads, as well as use the robot's unique agility for scouting missions in access‑challenged environments. This breakthrough showcases how advanced AI, physics‑based control and iterative simulation can produce robots that mimic human‑style tricks, pushing the boundaries of what is possible in small, mobile robotics.
Original source:
Head Topics
Comments 0